Equipment servicing
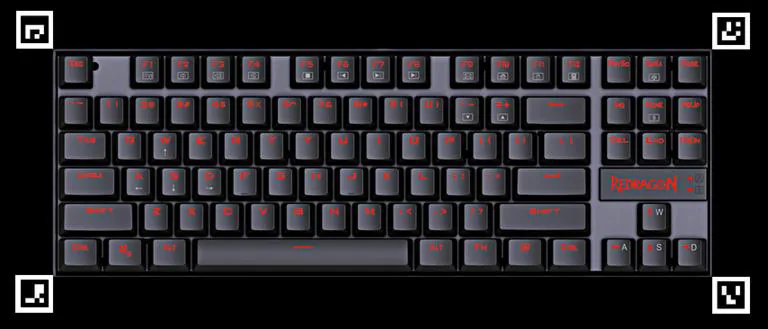
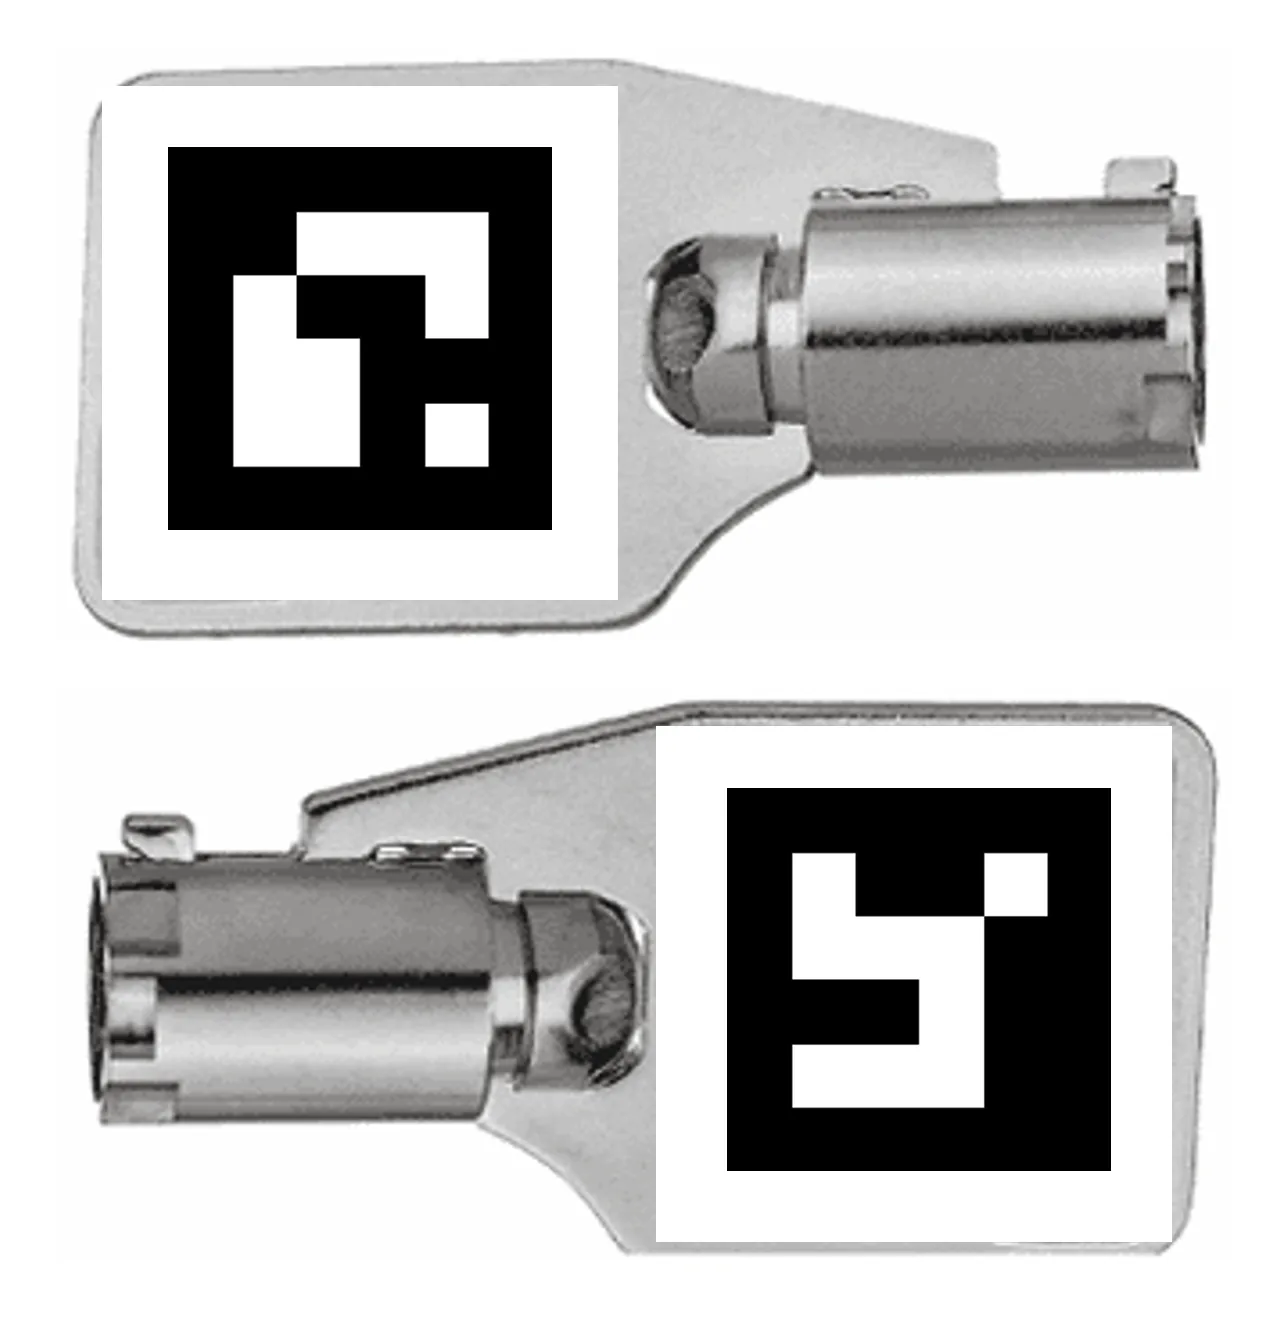
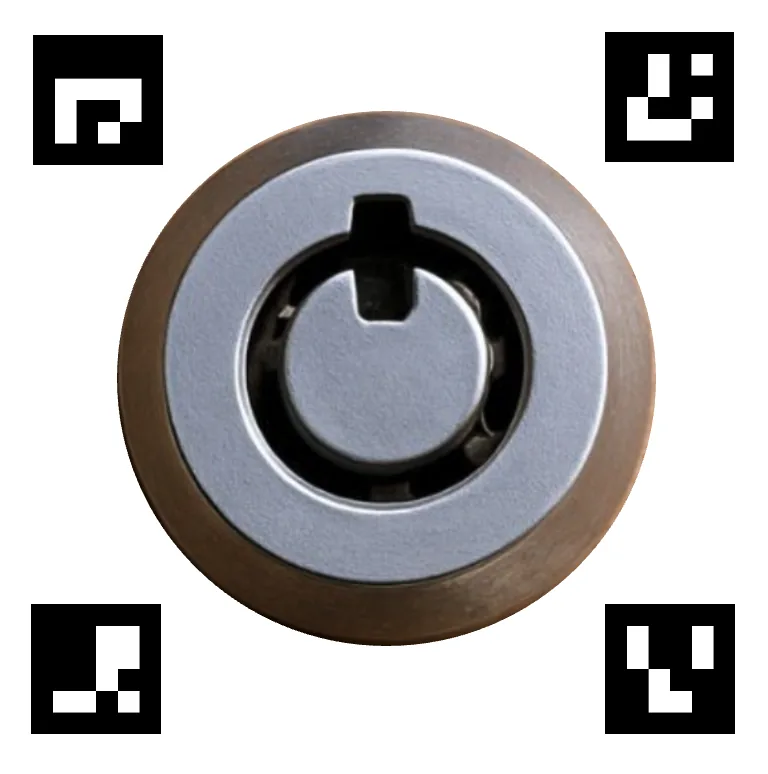
Equipment Servicing is the arm’s report card, and the field’s weakest mission after Autonomy. Nine task families span ground level to 1.5 m, and the smallest targets in the rulebook are 2 × 2 cm ArUco tags at the corners of a vertical keyboard and 1 × 1 cm tags on a key and a keyhole. The difficulty is manipulation itself, not the task list.
Key takeaways
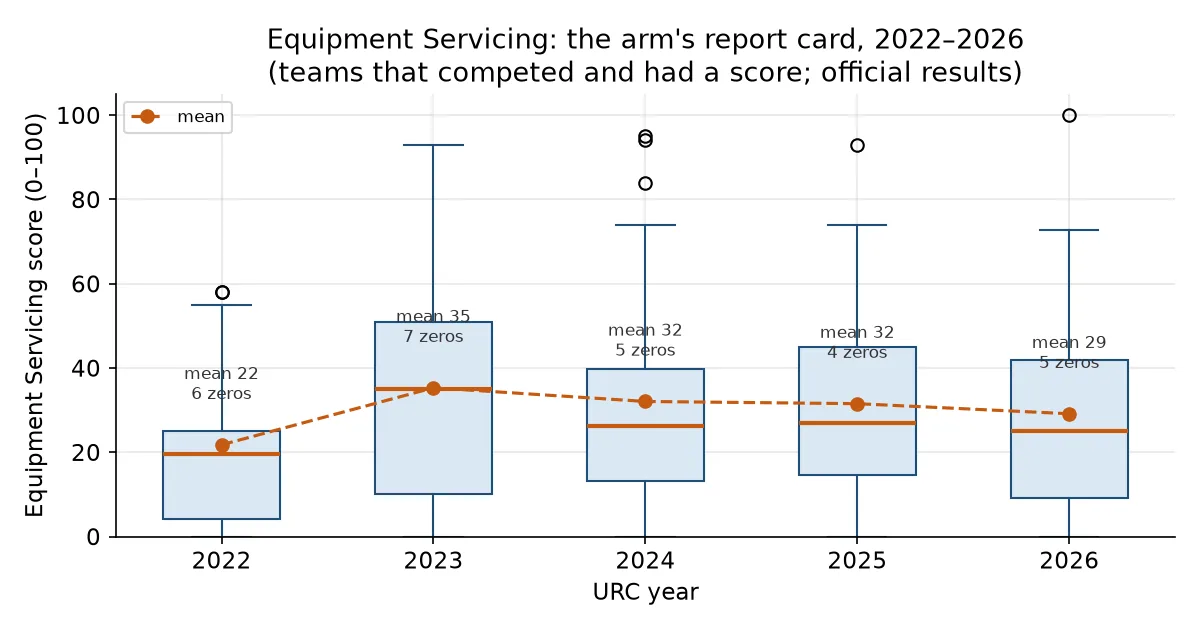
- The flat mean is the finding. The mission mean has stayed between 29 and 35 for four seasons despite rule changes, because the difficulty is manipulation itself rather than the task list.
- Open-loop precision does not exist at this scale. Planetary joint backlash of 15–18 arcmin is 4.4–5.2 mm at 1 m, wider than a keyway. Vision has to close the loop on typing and on the key.
- 2027 adds two hard tasks and removes one. The key in the tubular lock has no precedent, the hose is stiffer, and the USB Type-C task is gone. Per-task weights are unpublished in both years, so the five-year mean is the base rate.
- A mid-cost arm reaches the middle of the field. UIU’s 72.63 came from a 6-DoF arm, an ArUco-aligned typing routine and a rehearsed mock lander S-UIU-2026-SAR.
What the mission physically demands
| Demand | Number | Basis |
|---|---|---|
| Workspace | Ground level to 1.5 m above ground, from an unspecified standoff; a 100 m traverse; 30 minutes | S-URC27-RULES §1.d.i |
| Task families | Nine, in any order: sample tube, cache transport, drawer, latch and panel, typing, key and lock, hose, quarter-turn valve, buttons and switches | S-URC27-RULES §1.d.ii |
| Keyboard | Redragon K552, 87-key tenkeyless, 354 × 123 × 37 mm, 875 g, 19.05 mm key pitch, about 0.44 N actuation over 2 mm of roughly 4 mm travel, no auto-repeat | S-URC27-TASKHW |
| Keyboard tags | 2 × 2 cm ArUco 4x4_50 markers at the four corners | S-URC27-RULES §1.d.ii |
| Key and lock | A flat key with a 1 × 1 cm tag on the bow, a standard 7-pin tubular keyway with 1 × 1 cm tags at the four corners of the face, and a 1–2 mm keyway to align to | S-URC27-RULES §1.d.ii |
| Accuracy budget implied | Backlash of 15–18 arcmin is 4.4–5.2 mm at 1 m | Datasheet values, by inference |
| Time per task implied | 30 minutes minus a 100 m traverse and nine families leaves about 2–3 minutes each, including approach and retreat | By inference; Monash 2022 spent about 4 minutes on the door latch alone across two attempts S-MONASH-ES22 |
| Contact rule | Every task must be doable with one gloved hand, and the keyboard must not be touched by hand | S-URC27-QA S-URC27-RULES §1.d.ii EQ1 |
What the best teams did
The record is consistent: a long tail of zeros, a handful of 93–100 runs, and a mean that does not move.
| Year | Teams | Mean | Median | Exact 0 | Scores ≥80 | Maximum |
|---|---|---|---|---|---|---|
| 2022 | 26 | 21.8 | 19.5 | 6 | 0 | 58 (Missouri S&T and IMPULS) |
| 2023 | 31 | 35.3 | 35.0 | 7 | 3 | 93 (AGH) |
| 2024 | 34 | 32.0 | 26.3 | 5 | 3 | 95 (BYU) |
| 2025 | 35 | 31.5 | 27.0 | 4 | 1 | 93 (Missouri S&T) |
| 2026 | 36 | 29.1 | 25.0 | 5 | 1 | 100 (Missouri S&T) |
Derived from the official mission column in the five result sheets S-URC22-SCORES S-URC23-SCORES S-URC24-SCORES S-URC25-SCORES S-URC26-SCORES.
| Team | 2022 | 2023 | 2024 | 2025 | 2026 | Architecture and lesson |
|---|---|---|---|---|---|---|
| Missouri S&T | 58 | 68 | 94 | 93 | 100 | A hybrid of one prismatic and five rotary axes, mounted on the top deck and chosen for precision on the panel face |
| BYU | 18 | 58 | 95 | 59.2 | 22.11 | A wrist sensor head with ViSP visual servoing; bimodal, 95 then 22 |
| AGH | 16 | 93 | 74 | did not enter | did not enter | 93 in 2023 was the field maximum |
| West Virginia | 25.2 | 85 | 84 | 43 | 38.95 | An over-torque cascade in 2023 and a damaged USB-C cable in 2026 that took out cameras and two motors |
| Monash | 53 | 82 | 18 | 54 | 58.95 | Every arm redesign scored worse than the design it replaced, 2023 excepted |
| UIU | 23 | 50 | 72 | 42.4 | 72.63 | A 6-DoF arm, ArUco typing and a rehearsed mock lander: the most replicable result in the record |
| MIST | 2021: 100 | 29 | 30 | 41 | 23.68 | The only complete judged run on video, from 2021; hobby servos once the tasks hardened |
Official Equipment Servicing column S-URC22-SCORES S-URC26-SCORES, with MIST’s 2021 result from its own competition record S-MIST-VURC2021.
The per-task pattern. Tasks where the object comes to the end effector are routine: buttons, switches, the drawer handle and the latch release. Tasks where the end effector must arrive at a precise pose in free space fail: typing, key insertion, the hose push and re-opening a panel. 2027 adds two of the second kind.
What 2027 changes
| 2027 change | Verdict |
|---|---|
| Key in a tubular pin-tumbler lock added | No precedent. 1 cm tags, a 1–2 mm keyway, and insertion and turn torque not yet measured |
| USB Type-C task removed | Invalidated. Fixtures, poses and rehearsal built for USB are obsolete, and one bankable task disappears |
| Hose: GatorLock with no gasket becomes a 1.5-inch cam lock with a half-thickness gasket | Invalidated hardware. 2026’s fitting was the easier push, so any 2026 tuning is to the wrong part |
| Display formally linked, at 4.2 inches on e-paper while the Q&A says 4.3 inches | Raised bar. A no-touch zone, the launch key read from the display, and judges who reset it |
| Buttons, switches, knobs, quarter-turn valve, latch, drawer, tube and cache | Carry forward |
| Per-task weights | Not published in either year, so no pricing of tasks is possible |
The net effect is not simply “harder”. Two hard tasks were added, one was removed, and the weights are unpublished. Anyone who assumes the 2026 mean carries over exactly is guessing in both directions.
Which subsystem options serve it
| Decision | Option A applies when | Option B applies when |
|---|---|---|
| Arm architecture | Five rotary axes plus one prismatic axis, with the rail parallel to the lander face, when Equipment is the priority: the best scores in the field use this layout | Six rotary axes for the least-surprising path with in-house machining; five axes plus a 400 mm lateral stage when the arm would otherwise be too long to stow |
| Rail caution | A prismatic axis must be designed for driving shock: Missouri S&T’s own vertical axis failed under driving in 2024 S-MST-NEWS2024 | A pure rotary arm if the rail cannot be made shock-proof in one season |
| Actuators | Integrated brushless modules with CAN and torque mode, to buy past driver development | Harmonic or cycloidal drives at the wrist when typing or the key task must work open-loop |
| End effector | A two-finger 100–110 mm jaw with a compliant typing tip, a chamfered key funnel and a hook or pin | A turret of several end effectors, never on a first build |
| Perception | A wrist camera at 1080p, 60–70° field of view, fixed focus at 0.2–0.5 m, for the 2 cm keyboard tags | A 5 MP camera if the 1 cm key tag needs margin; the mast camera cannot resolve 1 cm at task range |
| Typing | Two-stage visual servo: coarse inverse kinematics, then tag-based fine alignment, with each key confirmed | Open-loop typing only if wrist backlash is 0.5 mm or less |
| Order | The cheap tasks banked first, because any order is allowed | The hardest task first only if its weight dominates the gate, and that weight is unpublished |
| Transition | One arm configuration for both Autonomy and Equipment, so no re-weigh is triggered S-URC27-QA EQ4 | A tip swap inside the 10-minute window, never a module swap |
Minimum viable versus stretch
- The minimum that scores: one completed manipulation task. The cheapest are buttons, switches, knobs, the quarter-turn valve and the hinged latch.
- The mid-field: four to six tasks banked. UIU’s 72.63 in 2026 shows this band is reachable with a mid-cost 6-DoF arm and a rehearsed panel.
- The stretch: all nine families, including typing, the key transfer and the hose. One team did it for 100 in 2026, with a prismatic-axis arm and a dedicated typing tip.
Risks to retire early
| Risk | Why it is real | The test that retires it | Lead time |
|---|---|---|---|
| Key dropped or lost | The task is new and a dropped key ends it, possibly for both locks | A tethered key, a mechanical stop in the jaw and a drop test over a padded tray: 50 of 50 grasps, retained through 20 shakes and a 1 m drop | 5 months |
| Key will not insert or turn | A 1–2 mm keyway against 4.4–5.2 mm of open-loop backlash at 1 m | The same class of 7-pin lock, with insertion force and turn torque measured and the keyhole tags used for visual servoing: 20 of 20 insertions | 5 months |
| Hose will not seat | The gasket is now half thickness, and 2026 tuning was to a fitting with no gasket | An exact 1.5-inch cam-lock mock, with force logged against depth over 50 cycles and a retention pull to confirm the connected state | 4 months |
| Over-torque cascades to other subsystems | West Virginia in 2023 lost its arm cameras through a USB hub, and in 2026 lost cameras and two motors to a damaged cable S-WVU-YT-DOORFAIL S-WVU-NEWS2026 | Per-joint current limits and fault-isolated camera paths, so that no single cable takes out more than one camera and no motor | 4 months |
| Typing misalignment or a double press | Backlash, motion blur and no auto-repeat | One hundred automated presses at 3 mm offsets, each key confirmed by camera: 95 % correct on 3–6 letter keys, including a backspace correction | 4 months |
| Panel slips closed | Monash 2022 lost about 9 minutes to two closures S-MONASH-ES22 | A prop or hook that holds the panel, rehearsed as its own step: the panel stays open hands-off for 60 seconds | 3 months |
| Drawer jam or the rover pulled | The insertion is tight-fitting and the pull force is unmeasured | A mock drawer across a range of clearances: ten insertions at the tightest clearance with no rover motion | 3 months |
| Time runs out | About 2–3 minutes per task and a 100 m traverse inside 30 minutes | A timed full run on a mock panel in the real order: six tasks banked in 20 minutes | 3 months |
| The 10-minute transition | Any change in mass or configuration forces a re-weigh S-URC27-QA EQ4 | Autonomy, weigh-in and Equipment rehearsed inside the window: 8 minutes end to end, five runs in a row | 2 months |
| Wrong button or switch | One mis-press can fail a task | A mock labelled exactly like the rulebook figures: 20 of 20 correct on a randomised sequence | 2 months |
What is not published
- The per-task weights, which is why tasks can be ranked by risk but not by points per minute.
- Every force, torque and travel for the key, the lock, the hose, the valve, the drawer, the latch and the switches. A mock and a load cell are the only route to a number.
- Whether the cache in this mission is the team’s own Astrobiology cache or a judge-supplied one, so the interface must work for both.
- Whether digits can appear in the typing sequence, since the rule says 3–6 letters.
- The 2027 partial-credit split for typing corrections.
Further reading
- Arm and end-effectors works the architecture, backlash budget and end-effector choices behind this page.
- Compute, sensors and perception covers the wrist camera and the tag geometry.
- Missouri S&T, UIU, BYU, Monash and West Virginia carry the Equipment evidence.
- What 2027 invalidates places the key, the USB removal and the hose change beside the other 2027 changes.
Sources for this page
- S-UIU-2026-SARUIU Mars Rover, SAR 2026 (video; AURION, 6-wheel to 4-wheel rocker transition, spring pivot, carbon-core wheel)Original
- S-URC27-RULESUniversity Rover Challenge 2027 – Requirements and GuidelinesOriginal Archived copy
- S-URC27-TASKHW2027 task hardware resolved from the rulebook's own hyperlinks (keyboard, display, hammer, hose)Print copy
- S-MONASH-ES22Monash Nova Rover, Equipment Servicing Task, field footage, URC 2022 (chaptered)Original
- S-URC27-QAURC2027 Questions & Answers (updated through 2026-10-11)Original Archived copy
- S-URC22-SCORESURC2022 Official ScoresOriginal
- S-URC23-SCORESURC2023 Official ScoresOriginal
- S-URC24-SCORESURC2024 Official ScoresOriginal
- S-URC25-SCORESURC2025 Official ScoresOriginal
- S-URC26-SCORESURC2026 Official ScoresOriginal Archived copy
- S-MIST-VURC2021"Virtual URC 2021: MIST Mongol Barota, Session 1" on the official University Rover Challenge channel (1:20:42, uploaded 2021); full judged run: weigh-in 42.1 kg, box check 1.047 m, Equipment Servicing 100/100, Autonomous Navigation failure + manual intervention; auto-caption transcript retrieved with yt-dlp,write-auto-subOriginal
- S-MST-NEWS2024MRDT Newsletter Winter 2024–25 (PDF, 7.5 MB), URC 2024 review with failure forensics, 2025 design update, 88 active membersOriginal
- S-WVU-YT-DOORFAILFailure: Wanderer Struggled to Close a Door with a Broke Arm and Under Strong Wind During URC 2023Original
- S-WVU-NEWS2026WVU robotics team places fourth overall, earns top marks at international University Rover ChallengeOriginal