UMD Loop (University of Maryland, College Park)
UMD Loop publishes the most complete ROS 2 autonomy stack in this group: a workspace built on Nav2, with behaviour-tree nodes for AR-tag and object detection. At its only URC finals the rover, Athena, scored zero in the autonomy mission and finished 32nd of 36 in 2026, with Delivery at 5 and Equipment Servicing at 17.89. The stack is the design to copy; the result is the warning about integration time.
What this team shows
- A public ROS 2 workspace with Nav2, behaviour trees, ArUco and YOLO.
- Zero autonomy at the only finals, and three of four missions at or near zero.
- The integration practices are as valuable as the stack: DBC-generated CAN headers, SolidWorks to URDF, and Gazebo with ros2_control.
- A Nav2 configuration held as a submodule in one person’s account is a continuity risk.
Identity and results
UMD Loop is based at the University of Maryland, College Park. It appears in the 2024, 2025 and 2026 team lists, and only the 2026 score sheet carries a finals row S-URC24-TEAMS S-URC25-TEAMS S-URC26-TEAMS S-URC26-SCORES. Tier C is the census label for one finals; the tier rule is defined on the census page.
| Year | Rover | SAR | Science | Delivery | Equipment | Autonomy | Total | Rank | Field |
|---|---|---|---|---|---|---|---|---|---|
| 2026 | Athena | 80.71 | 60 | 5 | 17.89 | 0 | 163.6 | 32 | 36 |
2024 and 2025 were registered seasons with review films of 5:12 and 5:18 published, and no score-sheet row S-URC24-SCORES S-URC25-SCORES S-UMD-YT. Whether the review was rejected or the team withdrew is not stated. No UMD Loop row appears in the archived 2013–2019 tables S-URC-HISTRESULTS. The site describes 2026 as the team’s fourth year of the URC, which by inference puts the first cycle around 2023 S-UMD-SITE.
Two Maryland rover teams exist. The URC lists both UMD Loop and Robotics@Maryland, the Terraformers, in 2024–2026; they are separate clubs and must not be merged in any comparison S-URC24-TEAMS S-URC25-TEAMS.
Rover generations
Athena (2025–2026). The 2025–26 rover, named in the workspace description as “all the code for UMDLoop’s 2025-26 rover, Athena” S-UMD-GH-ATHENA. The site lists a rocker suspension, an on-board life-detection system, a six-degree-of-freedom arm and autonomous navigation S-UMD-SITE.
Before the URC. The team competed in the Hyperloop and Not-a-Boring competitions, and a 2019 Hyperloop pod codebase is still in the organisation S-UMD-SITE S-UMD-GH.
Subsystems
Mobility. Rocker suspension S-UMD-SITE. Wheel count, geometry, motors and mass are not published.
Arm and end-effectors. Six degrees of freedom S-UMD-SITE; Equipment Servicing scored 17.89 in 2026 S-URC26-SCORES. Actuators and end effector are not published.
Science. An on-board life-detection system is named S-UMD-SITE, and the organisation holds spectrometer code S-UMD-GH. Science scored 60 in 2026 S-URC26-SCORES.
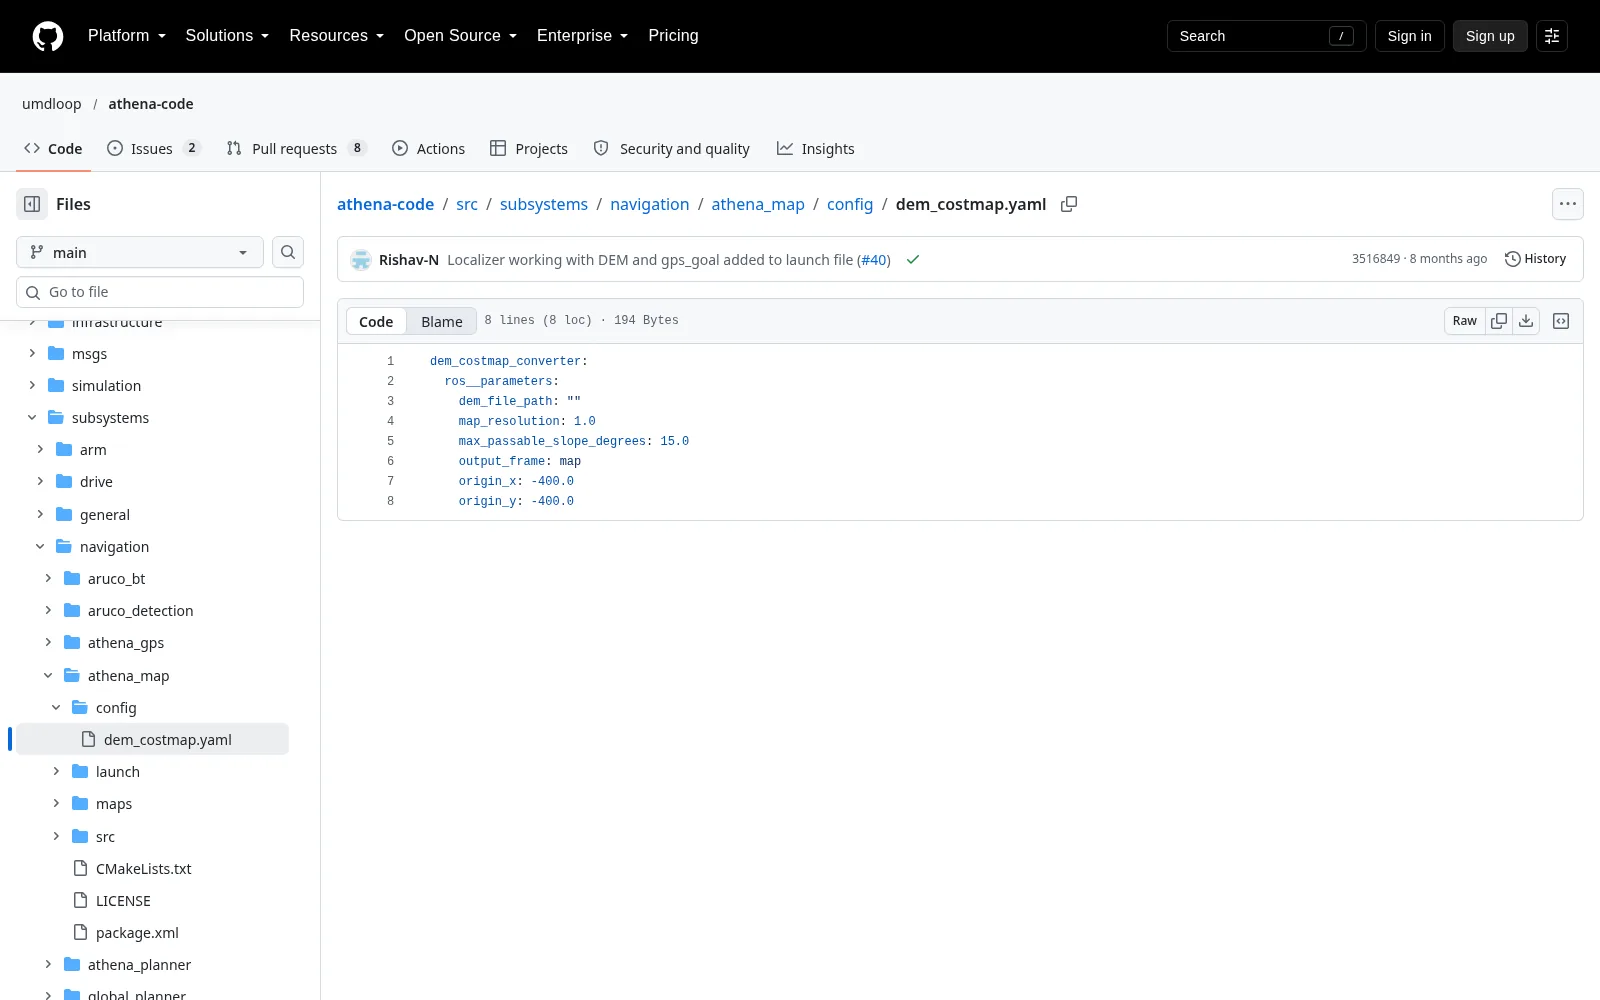
Autonomy. The workspace is organised by subsystem: arm, drive, general, navigation and science packages, with bringup, description, hardware interfaces, messages, simulation and teleoperation alongside S-UMD-GH-ATHENA. The navigation set includes a Nav2 configuration, a global planner, a vector-field planner, a waypoint manager, a mission executive, localisation, GPS goal and pose nodes, obstacle detection and a status LED package. AR-tag and YOLO detection are wrapped as behaviour-tree nodes S-UMD-GH-ATHENA.
Middleware and bus. CycloneDDS for the data plane, CAN with ODrive motor controllers for actuation, and C++ headers generated from a DBC bus definition so firmware and software share one message contract S-UMD-GH-ATHENA S-UMD-GH.
Simulation and model. SolidWorks to URDF, and Gazebo with ros2_control, so the CAD model is the simulation model S-UMD-GH.
Operator and communications. An operator GUI, camera streaming, telemetry radio utilities and status-lighting firmware S-UMD-GH.
Mission performance
2026, 32nd of 36 with 163.6. SAR 80.71, below the field’s stronger reviews (the top was 96.75); science 60, delivery 5, equipment 17.89 and autonomy 0 S-URC26-SCORES. One mission scored respectably, and the three that need a tested arm or a tested autonomy pipeline did not.
The gap that matters: a public Nav2 stack with AR-tag and YOLO behaviour trees produced zero in autonomy S-UMD-GH-ATHENA S-URC26-SCORES. The stack may not have been integrated onto the rover in time, the field run may have failed, or the mission may not have been attempted; public data cannot separate them.
Lessons for a first build
- Behaviour trees are the right shape for the autonomy mission. Drive to a point, detect a tag, stop within tolerance and report status: each step is a node and each node is testable in simulation S-UMD-GH-ATHENA.
- Generate the bus contract. C++ headers generated from a DBC file stop firmware and software from disagreeing about message identifiers, and the cost is one afternoon at the start of the season S-UMD-GH.
- Make the CAD model the simulation model. SolidWorks to URDF and Gazebo with ros2_control give a small team useful simulation coverage without a second model S-UMD-GH.
- Keep shared configuration in the team organisation. The Nav2 configuration is a submodule pointing at one person’s account; if that account changes, the documented build breaks for everyone S-UMD-GH-ATHENA.
- Plan integration before the stack grows. The autonomy code is the most complete in this group and produced zero. Integration time, not code volume, is the constraint.
What remains uncertain
Why autonomy scored zero and Delivery five with a complete stack is unexplained, and no post-event report exists. Why the 2024 and 2025 seasons ended before the score sheet is not stated. Mass, wheels, suspension geometry, arm actuators, science instrument, battery, radio and on-board computer are unpublished; the site names systems but gives no numbers. Whether the drone work is an active subsystem is unclear, with a vendored MAVSDK package as the only evidence. Team size, and how much of the Hyperloop-era membership carried over, is not published.
Team sources
- umdloop.com, the team site with the system list and the URC history.
- umdloop on GitHub, thirty public repositories active into 2026.
- athena-code, the ROS 2 workspace for the 2025–26 rover.
- UMD Loop on YouTube, the 2024, 2025 and 2026 review films.
Sources for this page
- S-URC24-TEAMSURC2024 Team ListOriginal
- S-URC25-TEAMSURC2025 Team ListOriginal
- S-URC26-TEAMSURC2026 Team ListOriginal Archived copy
- S-URC26-SCORESURC2026 Official ScoresOriginal Archived copy
- S-URC24-SCORESURC2024 Official ScoresOriginal
- S-URC25-SCORESURC2025 Official ScoresOriginal
- S-UMD-YTUMD Loop YouTube channel, "UMD Loop URC SAR 2026" (4:53), "UMD Loop SAR 2025" (5:18), "UMD LoopPrint copy
- S-URC-HISTRESULTSURC results database: derived 2022–2026 statistics (§4–§5) and archived official results 2013–2019 (§7)Print copy
- S-UMD-SITEUMD Loop site, founded by President Pines, 10+ years, prior Hyperloop / Not-a-Boring competitions, "4th year of URC"; rover features: rocker suspension, life-detection system, 6-DOF arm, autonomous navigationOriginal
- S-UMD-GH-ATHENAumdloop/athena-code, "all the code for UMDLoop's 2025-26 rover, Athena"; ROS 2 workspace; src/subsystems/{arm,drive,general,navigation,science}; config/cyclonedds; config/odrive_config; nav2_config git submodule → sutharsan-311/nav2_config; nav packages nav_bringup, athena_planner, global_planner, vector_field_planner, waypoint_manager, mission_executive, localizer, athena_gps, gps_goal, gps_pose_publisher, mag_heading, athena_map, point_cloud_filterer, obstacle_detection, aruco_detection, aruco_bt, yolo_ros_bt, led_indicator; CAN setup scripts; colcon build,symlink-install; vendored MAVSDK.debOriginal
- S-UMD-GHgithub.com/umdloop, 30 public repos, most recent 2026-07-16: Electrical-PCBs, athena-code, STM32L476 firmware, CAN header generator + DBC parser, ODrive configs, ZED ROS 2 wrapper, YOLO repos, spectrometer scripts, operator GUIOriginal